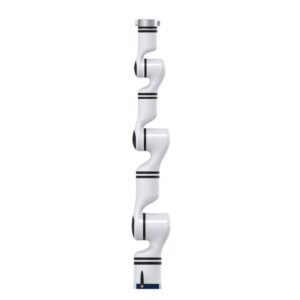
UFACTORY xArm 7 – 7-Axis Collaborative Robot Arm for Automation & Research
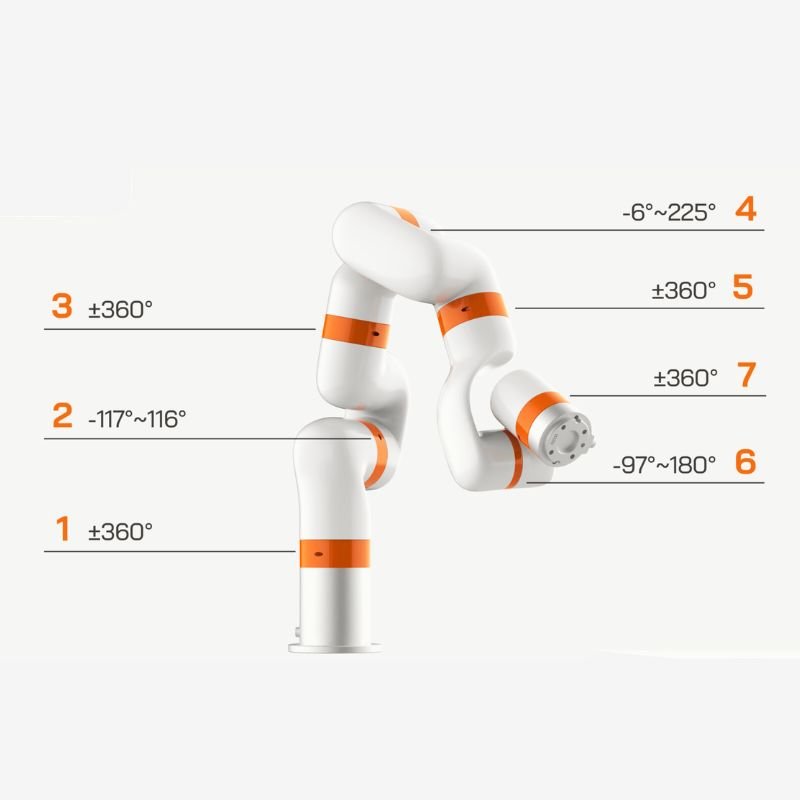
The UFACTORY xArm 7 combines seven degrees of freedom with a 3.5 kg payload capacity. Its additional joint provides flexibility for exploring complex arm poses and motion planning in research and laboratory environments.
Technical Specifications
| Parameter |
Specification |
| Degrees of Freedom |
7 axes |
| Maximum Payload |
3.5 kg |
| Position Repeatability |
±0.1 mm |
| Maximum End-Effector Speed |
1 m/s |
| Maximum Joint Speed |
180°/s |
| Construction |
Aluminum and carbon fiber |
| Base Footprint |
Ø126 mm |
| Programming |
UFACTORY Studio, Python, C++, and ROS |
| Controller Communication |
Ethernet |
| Operating Temperature |
0°C to 50°C |
Automation and Research Integration
Combine the arm with suitable grippers, cameras, and fixtures to develop manipulation experiments or automated handling workflows. Select tooling around the task’s geometry, gripping requirements, and cycle time.
Configuration and Installation
Include the end effector and workpiece when calculating payload. Confirm controller type, tool compatibility, mounting, and workspace requirements for your application.
Explore UFACTORY xArm 7 at RoboLearn
Contact robolearn.store for configuration inquiries, gripper options, pricing, and availability.
Reviews
There are no reviews yet.