Hiwonder SO-ARM101 – LeRobot Robotic Arm for Imitation Learning & Embodied AI
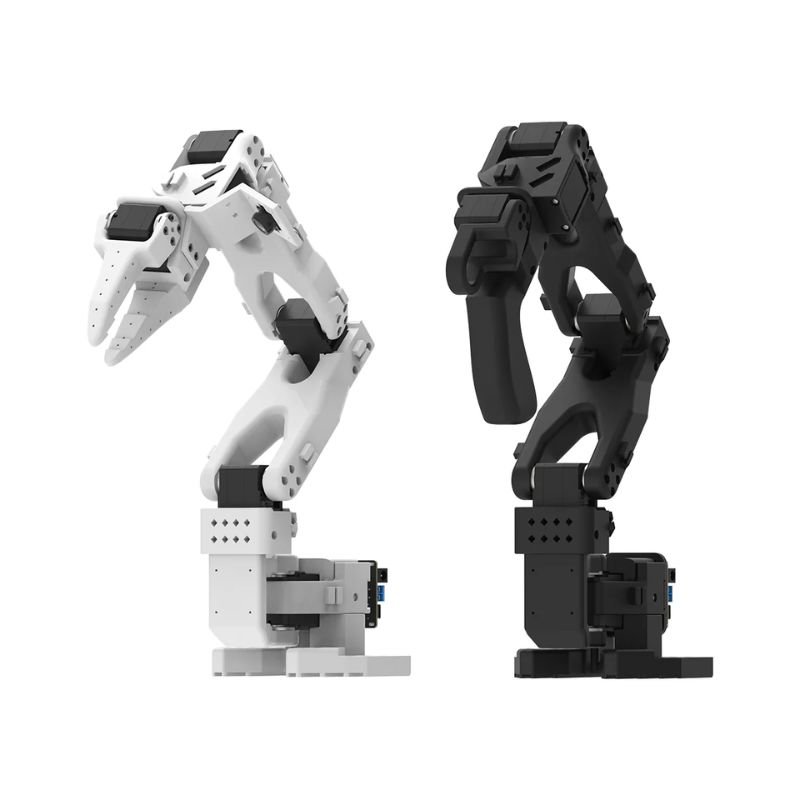
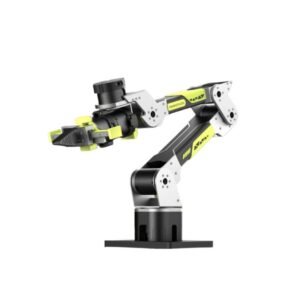
The Hiwonder SO-ARM101 is an open-source robotic arm platform for learning how robots acquire manipulation skills from demonstrations. LeRobot integration connects hands-on teleoperation with dataset collection and AI policy development.
Technical Specifications
| Feature |
Specification |
| Model |
Hiwonder SO-ARM101. |
| Structure |
PLA mechanical parts; six servo actuators per arm. |
| Leader Arm |
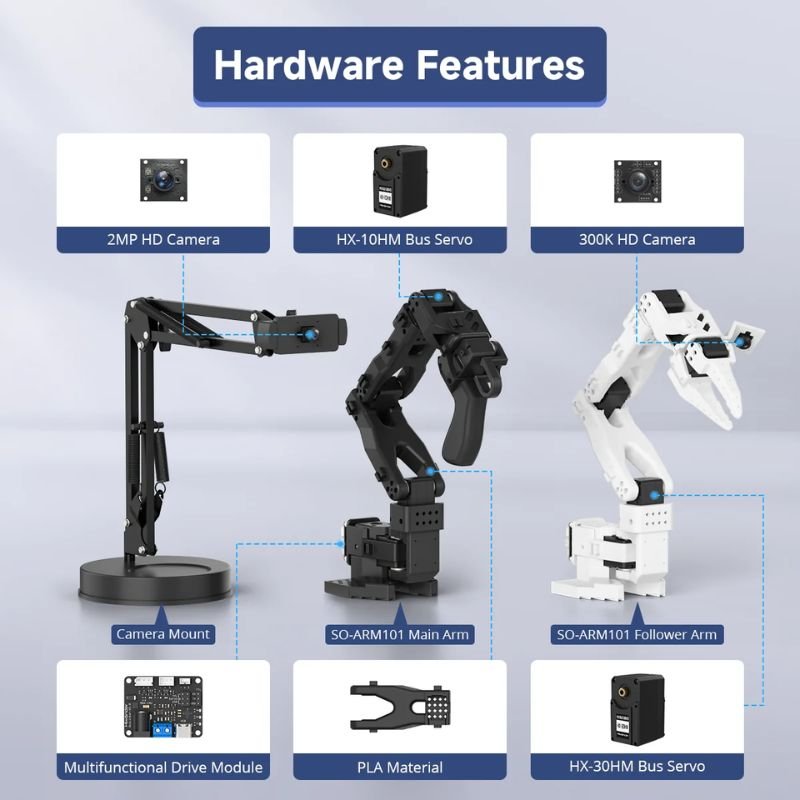
Six HX-10HM bus servos; 111 × 239 × 525mm; 697g. |
| Follower Arm |
Six HX-30HM bus servos; 111 × 173 × 532mm; 704g. |
| Controller |
BusLinker V3.0 servo debugging board. |
| Camera Options |
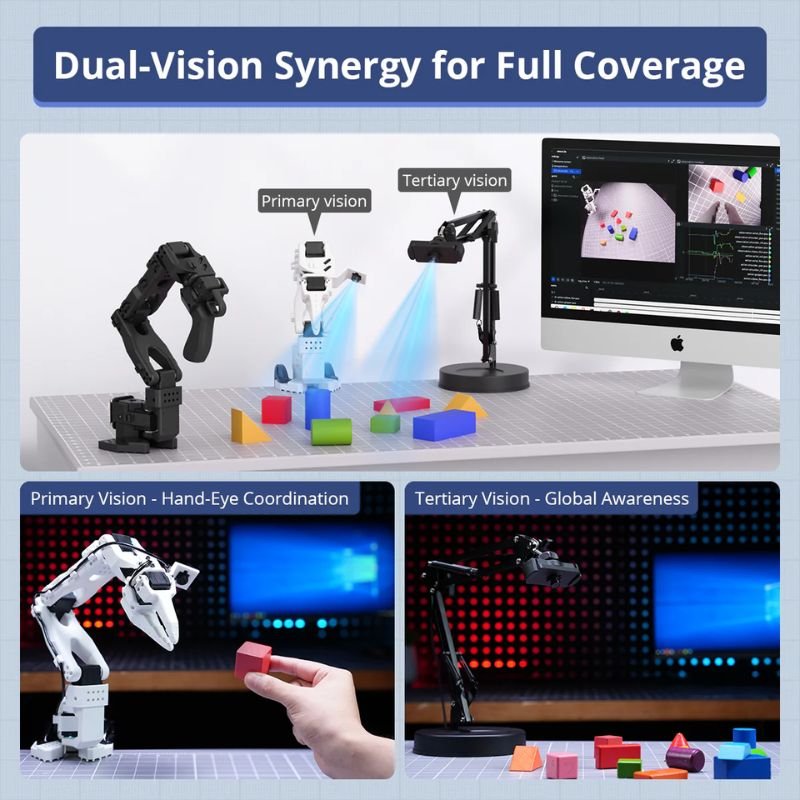
480p wide-angle camera and 2MP 1080p wide-angle camera; inclusion depends on kit. |
| Communication |
USB serial connection. |
| Programming & Host OS |
Python; Windows and Ubuntu, depending on the software workflow. |
| Power Supply |
12V 5A; DC 4.0 × 1.7mm connector. |
Teach Robot Skills Through Demonstration
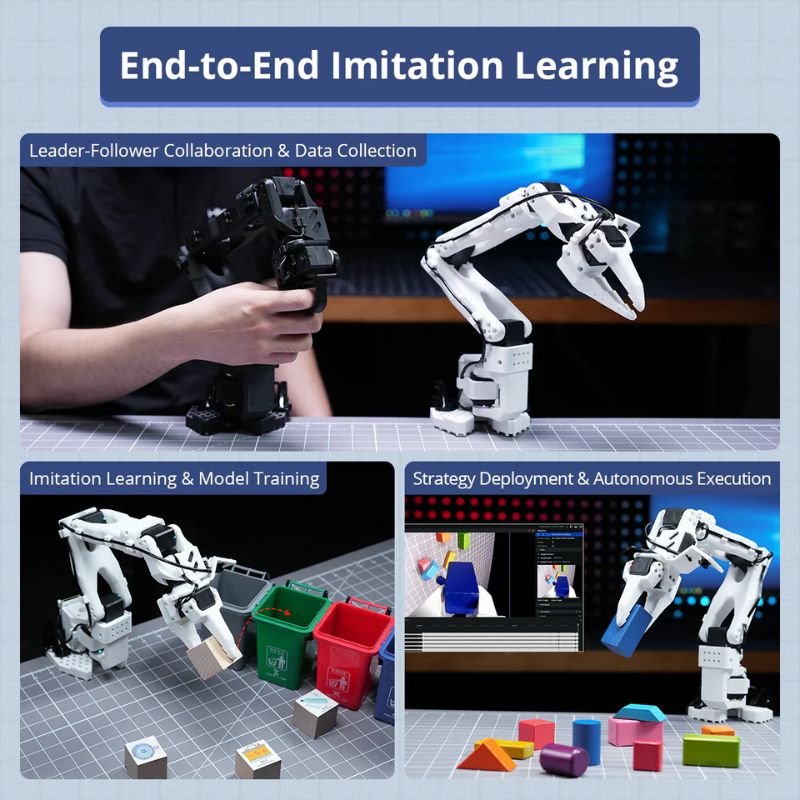
With a leader–follower setup, guide the leader arm while the follower reproduces its movements. This creates a practical starting point for demonstrating grasping, object transfer, and other tabletop manipulation tasks.
Record Datasets & Evaluate Learned Policies
Hiwonder’s LeRobot documentation covers recording demonstrations with camera observations and evaluating trained ACT policies. Use repeatable demonstrations to build datasets, train a policy with suitable computing resources, and assess how consistently it completes the task.
A Practical Platform for Robotics Education
Organize projects around calibration, teleoperation, data quality, and policy evaluation. Students can investigate how camera placement, demonstration consistency, and changes in object position affect learning outcomes.
Choose Your Kit Configuration
Hiwonder lists DIY, Starter, Standard, and Advanced packages. Confirm the number of arms, assembly status, cameras, mounts, and included accessories for your selected package before ordering.
Explore Hiwonder SO-ARM101 at RoboLearn
Contact RoboLearn for Hiwonder SO-ARM101 kit selection, compatible accessories, pricing, and availability.
thien_anh –
good