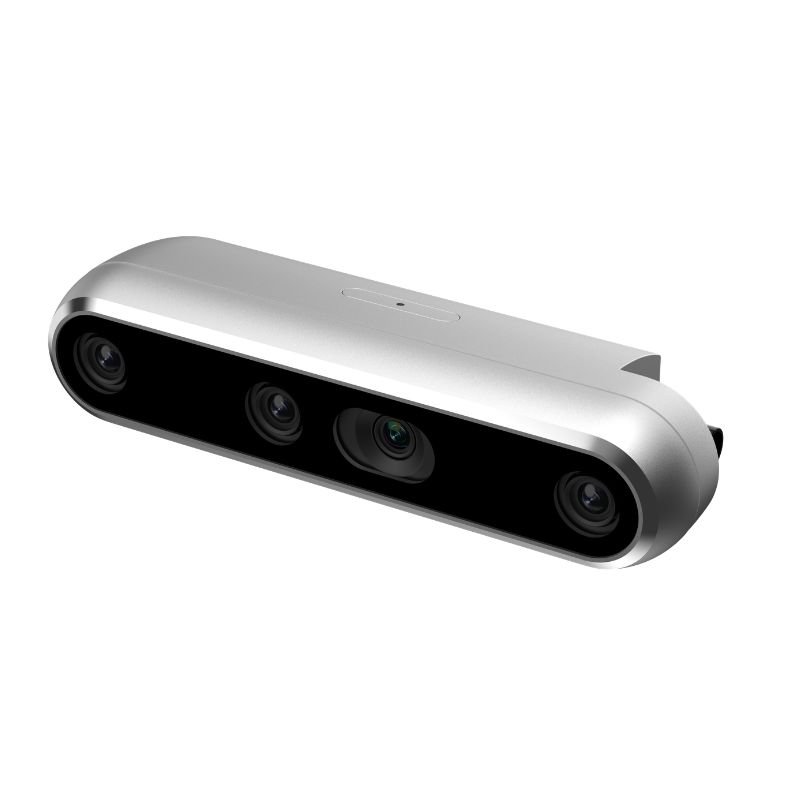
Intel RealSense D457 Stereo Depth Camera
The RealSense D457 combines stereo depth cameras, an RGB sensor, and inertial sensing in a rugged enclosure. Its RealSense Vision Processor D4 processes stereo images to generate depth data for robotic perception applications.
Depth and Color for Mobile Robotics
Global shutter imaging supports motion capture, while synchronized depth and color information can support environmental understanding. Suitable applications include autonomous mobile robots, automated guided vehicles, and obstacle-detection development.
Technical Specifications
| Parameter |
Specification |
| Depth Technology |
Stereoscopic depth sensing |
| Ideal Operating Range |
0.6–6 m |
| Depth Resolution |
Up to 1280 × 720 |
| Depth Frame Rate |
Up to 90 fps, depending on the selected stream profile |
| Depth Field of View |
87° horizontal × 58° vertical |
| RGB Camera |
Global shutter; resolution up to 1280 × 800 |
| Motion Sensing |
Integrated IMU |
| Interface |
GMSL2 with FAKRA connector |
| Enclosure Protection |
IP65 |
| Dimensions |
124 × 29 × 36 mm |
Software and Hardware Integration
Develop with the open-source RealSense SDK 2.0. GMSL operation requires a compatible host deserializer, appropriate cabling, and supporting kernel drivers. Confirm these components when selecting your system configuration.
Explore RealSense D457 at RoboLearn
Contact robolearn.store for product inquiries, integration accessories, pricing, and availability.
Reviews
There are no reviews yet.