MYACTUATOR RH-17 Harmonic Joint Actuator
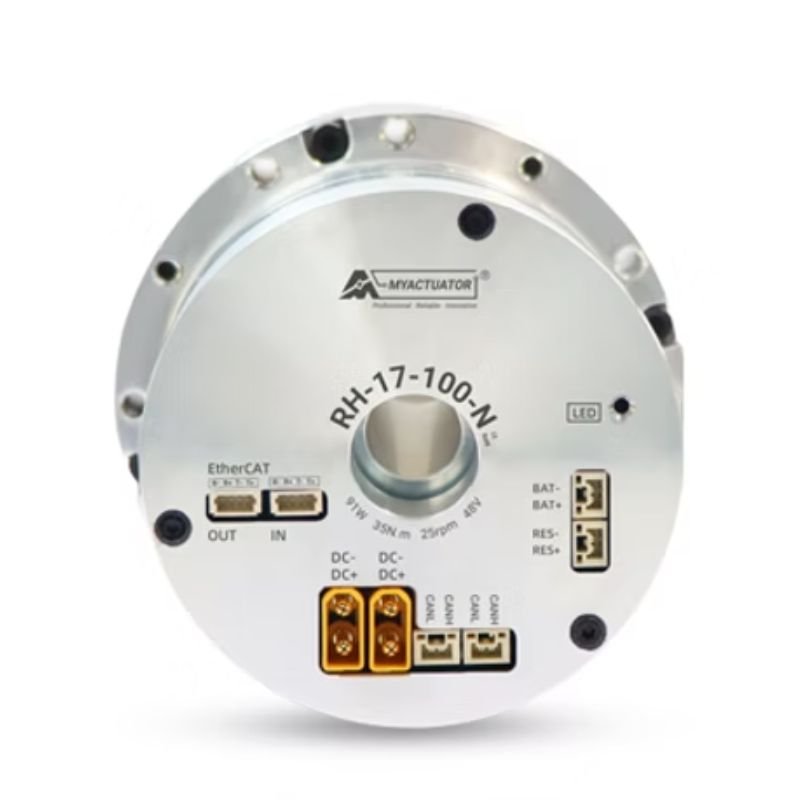
The MYACTUATOR RH-17 combines harmonic reduction with dual encoder feedback for robotic motion control. Brake and brake-free configurations provide options for different joint designs.
Technical Specifications
| Parameter |
Specification |
| Reduction Ratio |
100:1 |
| Supply Voltage |
48 V nominal; 20–55 V range |
| Rated / Peak Torque |
35 Nm / 54 Nm |
| Rated / No-Load Speed |
25 rpm / 30 rpm |
| Rated Power |
91 W |
| Encoder Feedback |
17-bit absolute input encoder and 17-bit absolute output encoder |
| Backlash |
≤40 arcseconds |
| Position Repeatability |
<0.01° |
| Communication |
CAN bus and EtherCAT |
| Weight |
1.11 kg without brake; 1.28 kg with brake |
Available Configurations
EPS-RH-17-100-E-N-D: without brake. EPS-RH-17-100-E-B-D: with brake. Both listed versions include dual encoders and CAN bus/EtherCAT support.
Integration Considerations
Select the actuator against your joint’s load, speed, duty cycle, and thermal requirements. Peak torque is not a continuous operating rating. Confirm mounting dimensions and environmental protection before ordering.
Explore MYACTUATOR RH-17 at RoboLearn
Contact robolearn.store for configuration inquiries, pricing, and availability.
Reviews
There are no reviews yet.